
Build real robots. Learn by doing. Share the knowledge.
Student-led robotics at ENSTA, Brest campus, with an open collection of robotics projects, experiments, teaching resources and historical work from across the ENSTA ecosystem.
Explore public repositories · Contribute & learn · Project origins & credit
From competition robots and autonomous boats to underwater perception, collaborative manipulation and simulation, we connect mechanics, electronics, embedded systems, control, perception and autonomy.
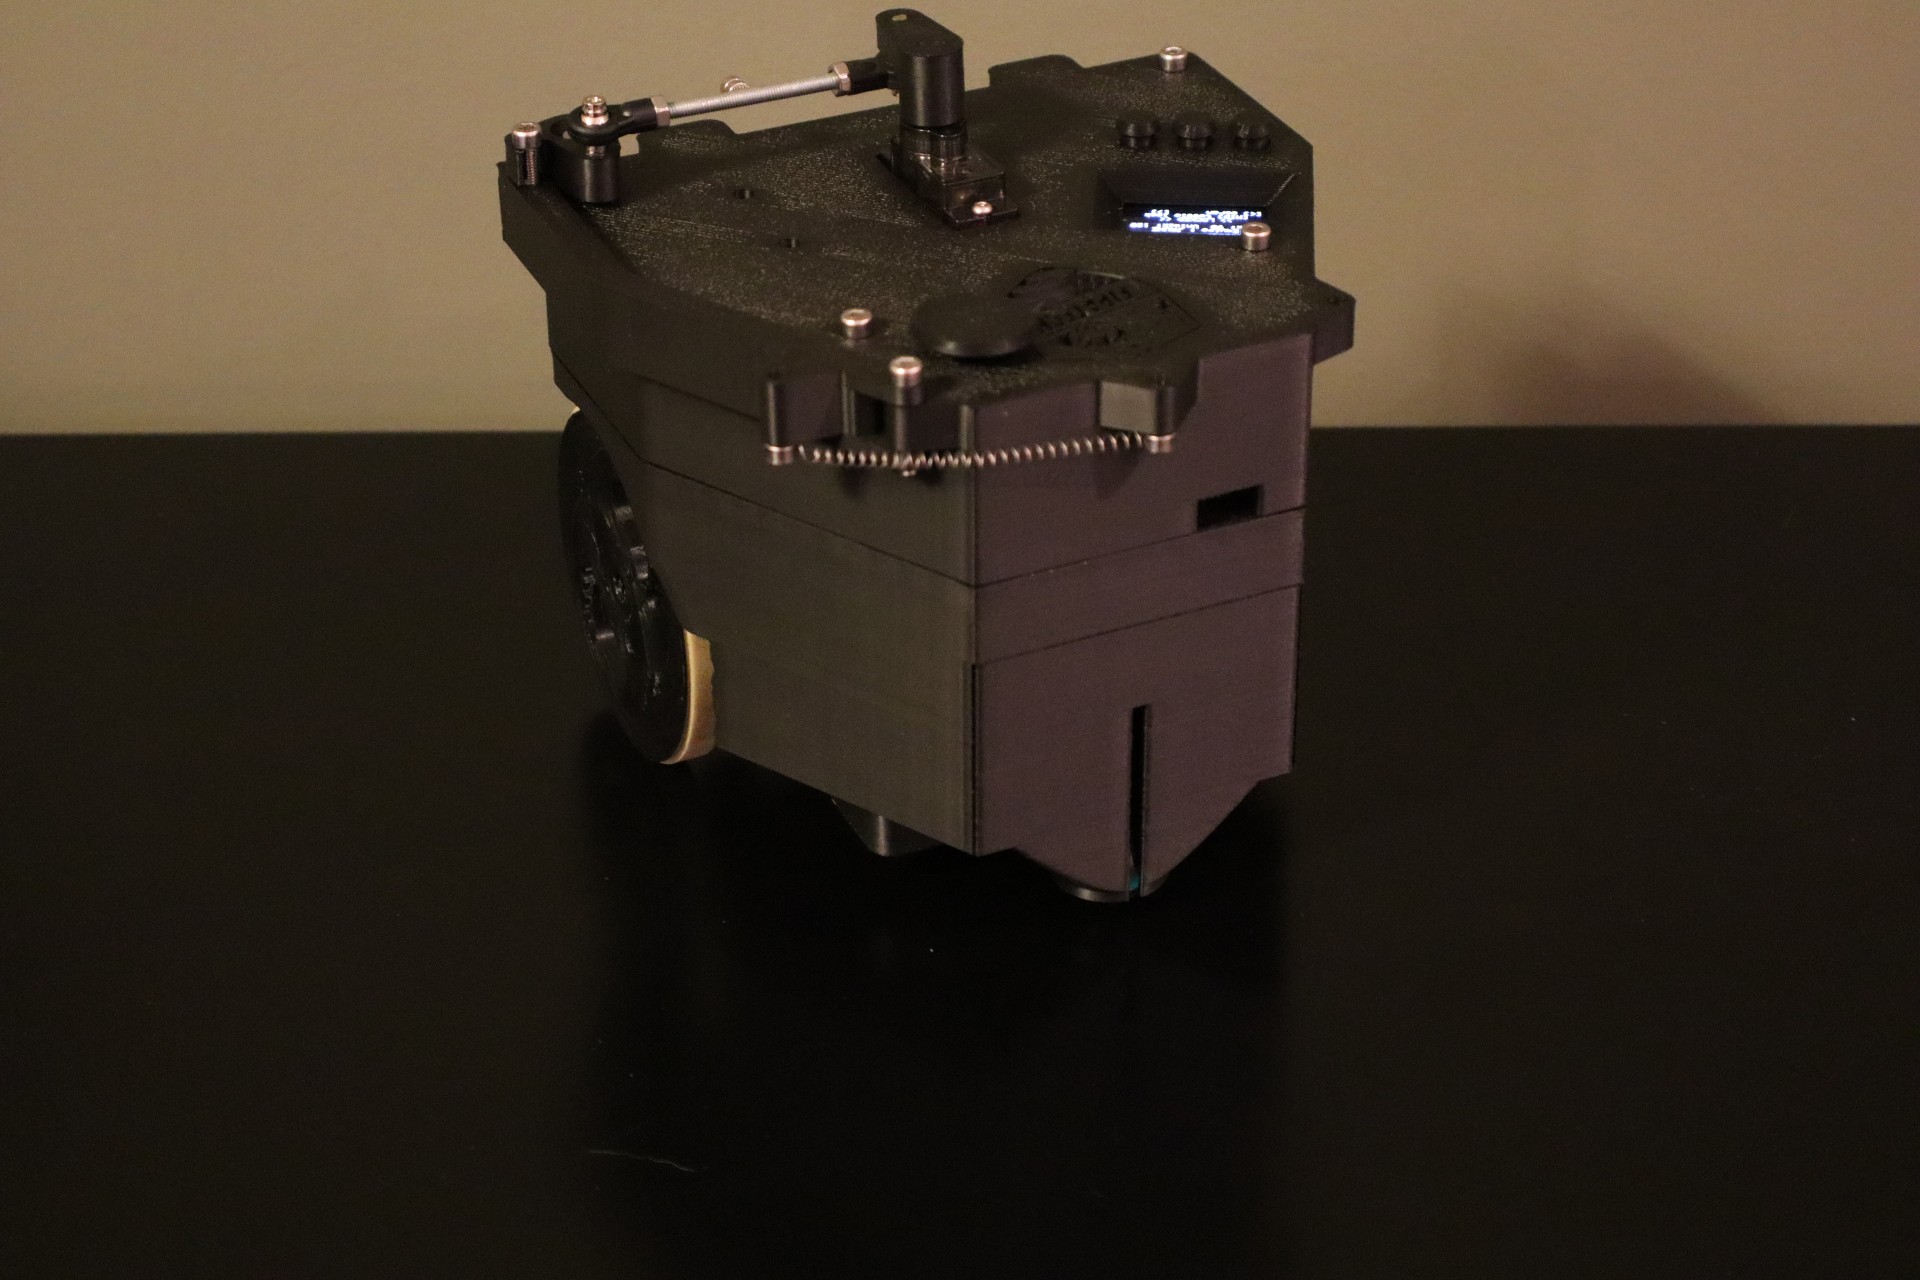
PAMI | French Robotics Cup ESP32-S3 firmware, a KiCad PCB, sensors, odometry and a Python control interface. Original work: FIPATECH |
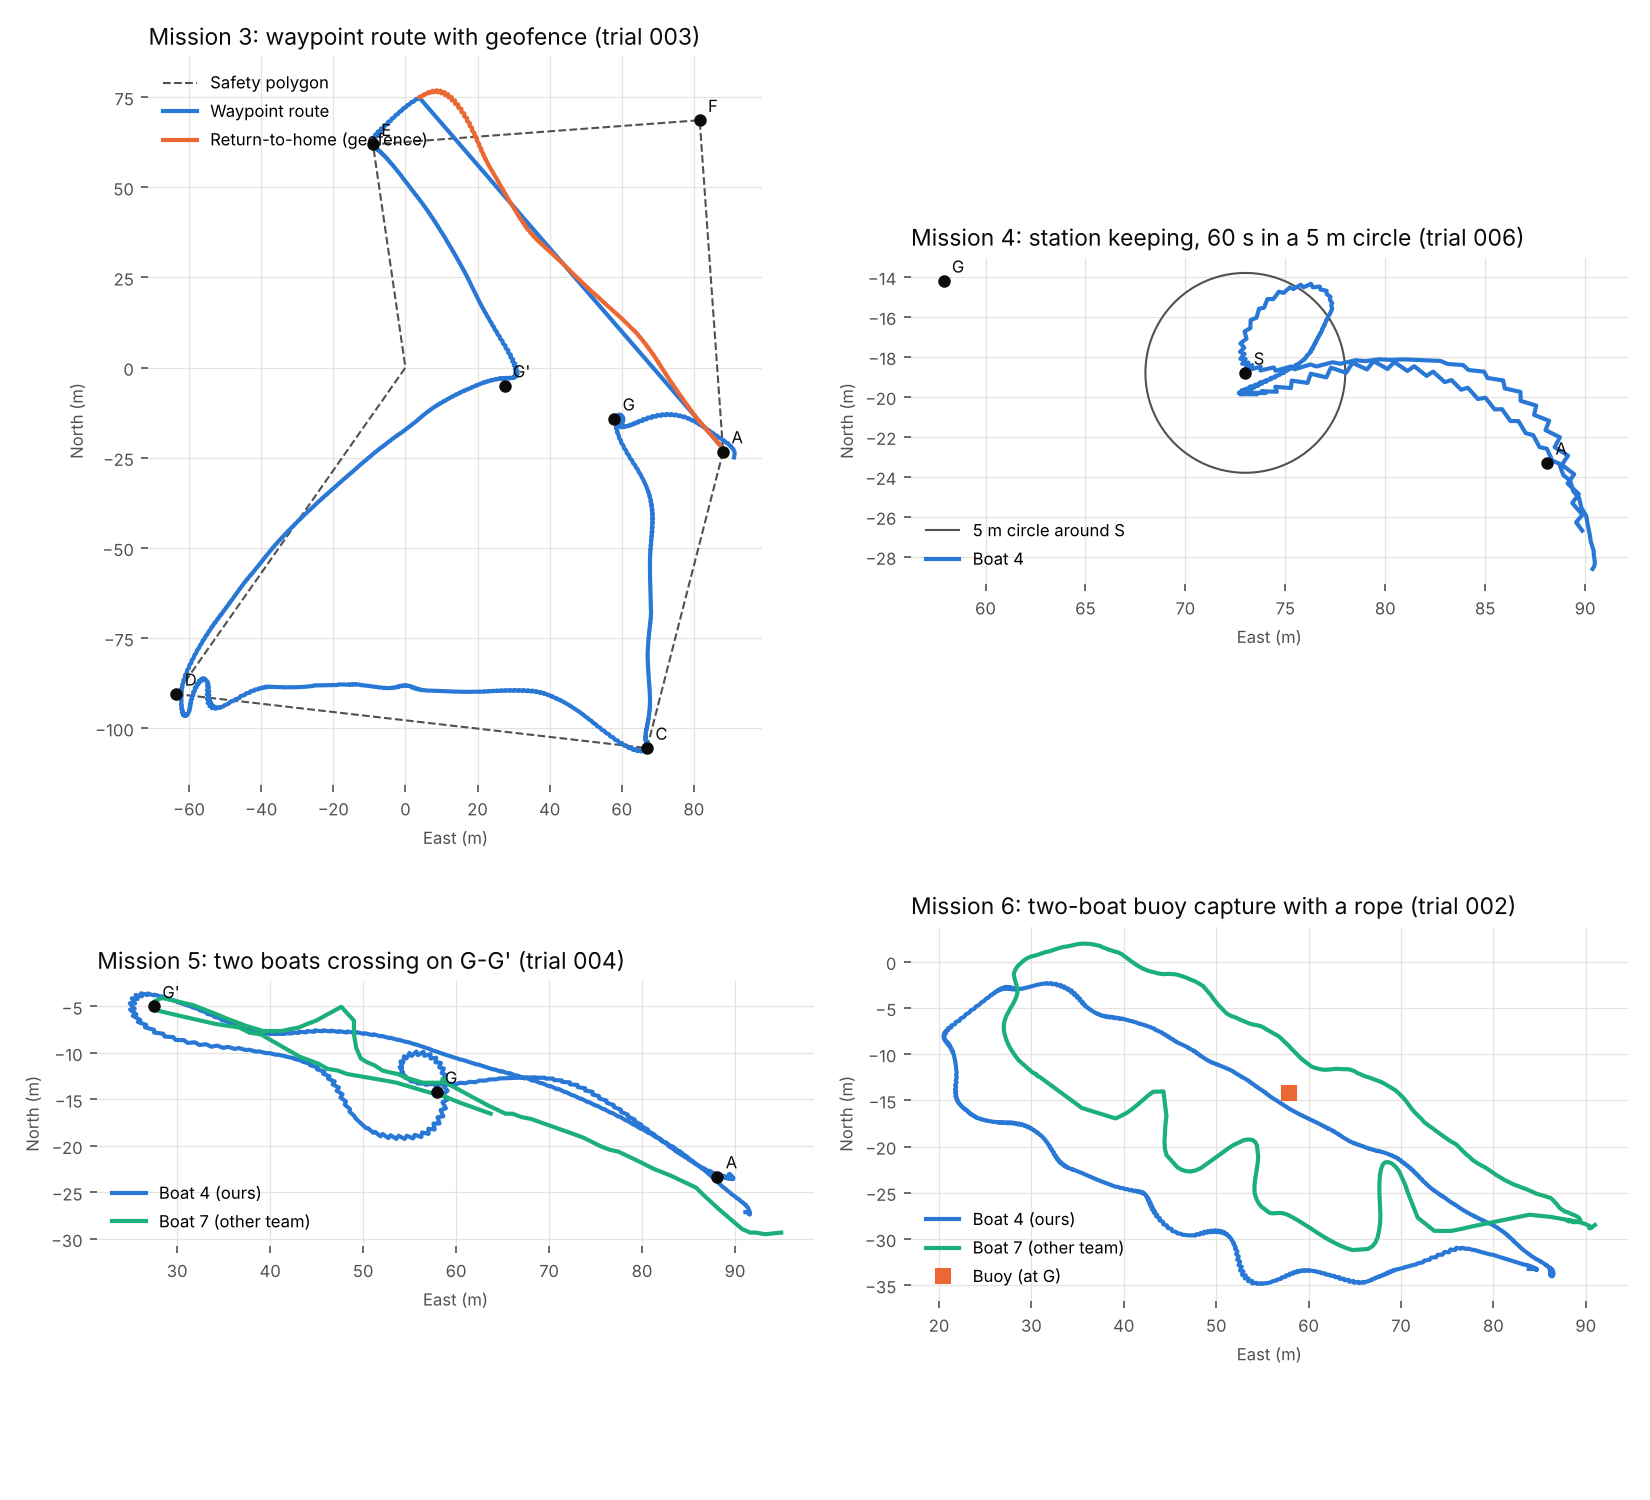
DDBOAT | Autonomous surface vessel GPS and Kalman filtering, guidance, safety and cooperative missions. Includes six field-mission logs. Original work: ENSTA Guerlédan team 4 |
The projects below combine real hardware, integration work, experimental results and usable documentation. They include projects by different student teams and preserved work from original contributors.
| Project | What you can explore | Origin |
|---|---|---|
| CDFR26_PAMI | Differential mobile robot, ESP-IDF, PCB, sensors and waypoint tools | FIPATECH |
| DDBOAT | Autonomous boat, six lake missions, test logs and reproducible figures | ENSTA Guerlédan team 4 |
| RacingRobot | Camera-guided racing car using Arduino, Raspberry Pi and computer vision | Original authors |
| robotic-franka | Franka Panda human-robot collaboration, real-robot demo, supervision and perception | ENSTA HRI course team |
| BlueRov2Project2A | ROS 2 visual servoing for a BlueROV2, tracking and mission state machine | Original student project |
| team-chouquette-cdfr26 | A second 2026 competition robot: Raspberry Pi, ESP32, serial protocol, vision and tests | Team Chouquette |
French Robotics Cup PAMI · Team Chouquette 2026 · RacingRobot · eURathlon 2015 ROS archive · Robot Dufur · Olympie reception robot
DDBOAT · DD-BOAT 5 · BlueROV2 visual servoing · Autonomous sonar docking · Cordelière · HELIOS ROS · HELIOS CATIA · BathyBoat navigation · BathyBoat web interface · Submarine 3D
Historical Guerlédan projects: ROS ground station, ROS BUBBLE, Black Box and lericard.
Franka collaborative manipulation · Robot arm calibration · Oculus sonar ROS 2 · Oculus C++ driver · RealSense + YOLO demo · ROS 2 audio manager · Magnetic calibration
RTAC sonar simulation · RTAC base · RTAC OptiX · RTAC display · RTAC ASIO · VIBES · Invariant library · Monocular depth rescaling
Historical Shepherd project: ROS structure, simulation, Unity display, localization and other components.
System design: HAUV aerial-underwater vehicle is a documented feasibility and simulation study, not a demonstrated operational vehicle.
New to Git or to the team's development workflow?
- GitHub basics, interactive tutorial
- Git with VS Code and the command line
- French interactive exercise toolkit
- GitHub Desktop for Linux (maintained fork)
We welcome students who want to learn by building, testing and documenting complete robotic systems. Browse a project README, report a reproducible issue, or propose a contribution in the repository concerned.
For related current initiatives, see FIPATECH (French Robotics Cup) and PHARE (student humanoid robotics project).
This organization is both a student-club workspace and a technical heritage collection. Not every repository here was created by the current ENSTA Robotics Club.
Some repositories are mirrors of publicly available work by earlier student teams, individual authors, research groups or independent projects. Their historical authorship belongs to the original contributors. Where available, the repository's website field links to the original source; individual README files describe licenses, credits and technical limitations.
Some repositories are research prototypes, course projects, partial archives or simulations rather than deployable products. We distinguish demonstrated results from proposed designs and retain historical context instead of claiming all work as our own.
Build robots. Share knowledge. Keep the next generation moving.
Discover the open repositories
